Key Takeaways
- Drone software development covers everything from flight-controller firmware on the aircraft to ground control, fleet management, data processing and AI analytics in the cloud.
- Most commercial projects do not write a flight stack from scratch. They build on PX4 or ArduPilot over the MAVLink protocol, or on a manufacturer SDK such as DJI’s.
- The business value usually sits above the flight layer: mission planning, fleet and pilot management, and turning aerial imagery into maps, measurements and alerts.
- Regulation is a software requirement, not an afterthought. India’s Drone Rules, 2021 and the Digital Sky airspace map, and the FAA’s Part 107 and Remote ID rules in the US, all shape what the software must enforce and log.
- Simulation-first testing (software-in-the-loop, then hardware-in-the-loop) is the safest way to ship changes to software that controls an aircraft.
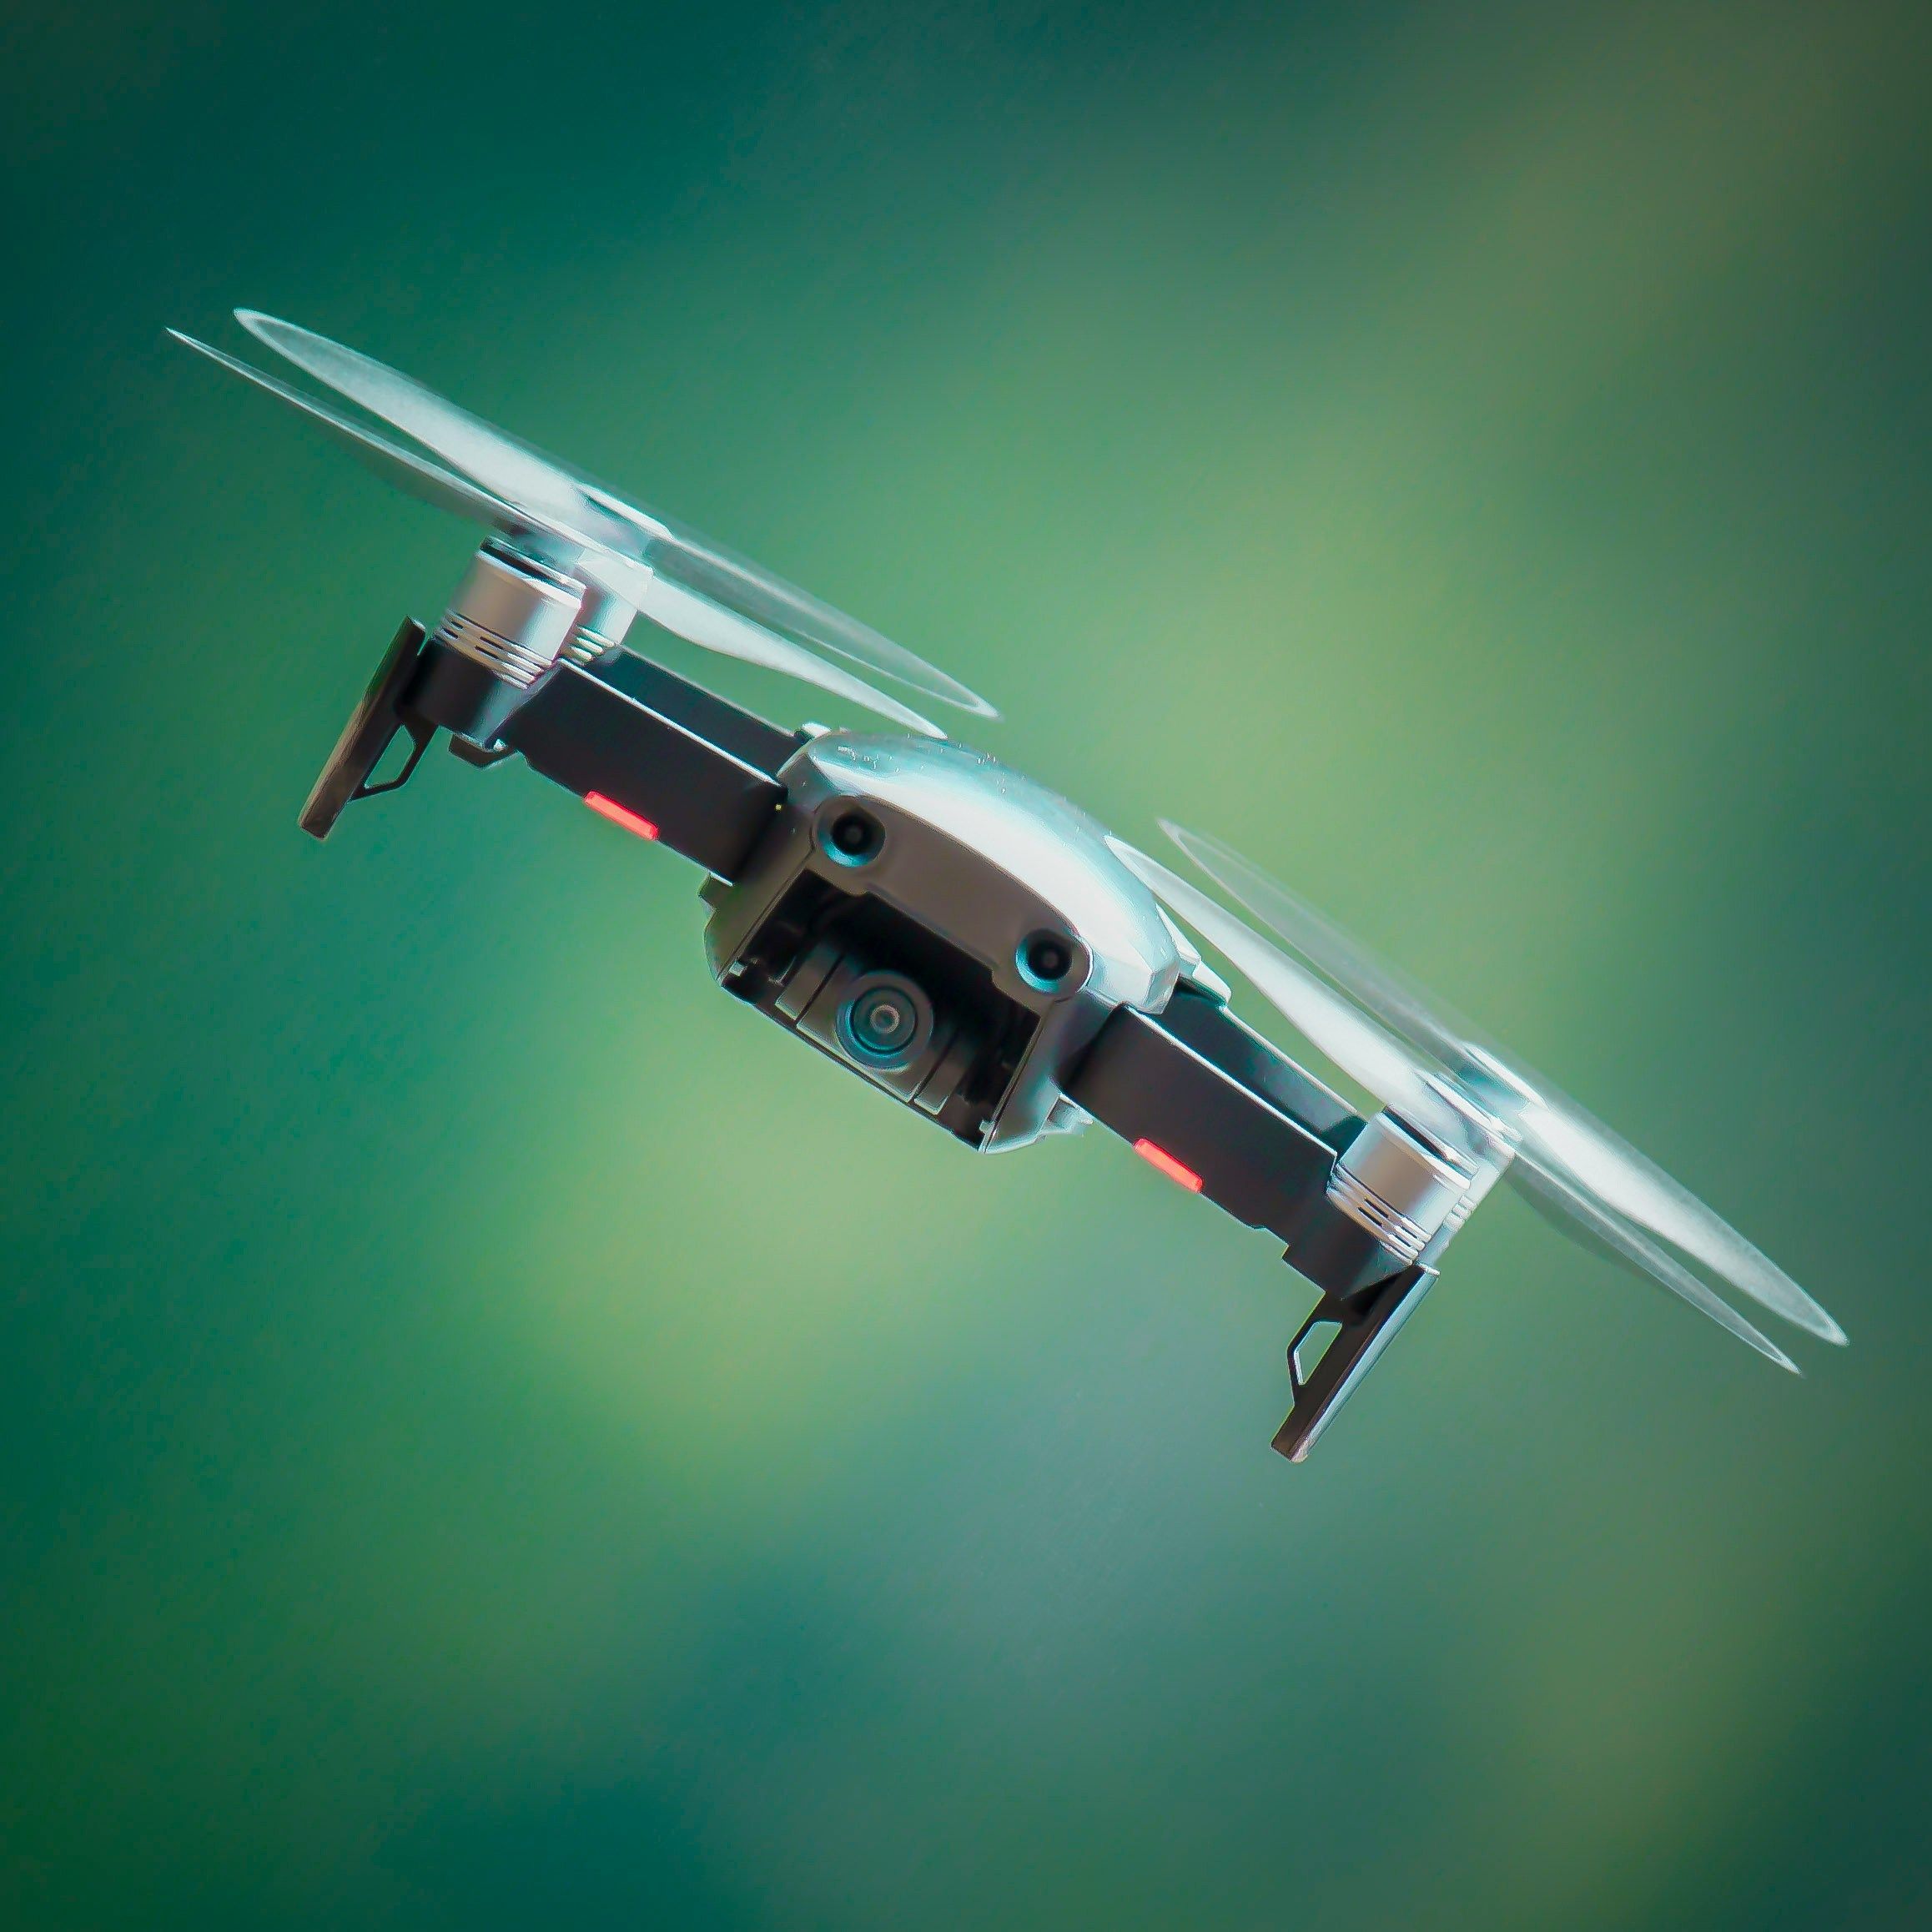
Drone software development is the work of building the software that flies, manages and makes sense of unmanned aircraft: flight-control firmware, ground control apps, fleet management platforms and the pipelines that turn aerial images and sensor data into maps, measurements and alerts. Most business value comes from the layers above flight control.
This guide is written for product owners and engineering leads planning a drone software project. It explains how a drone software stack is put together, which open-source and vendor tools teams usually build on, where the software earns its keep in enterprise use, and which rules in India and the United States the software has to respect.
What is drone software development?
A drone is a flying computer. The airframe, motors and battery get it into the air, but software decides how it stays stable, where it goes, what it records and what happens to that data afterwards. Drone software development is the discipline of designing, building, testing and maintaining that software.
It spans very different kinds of engineering. At one end is hard real-time embedded code that reads gyroscopes and adjusts motor speeds hundreds of times a second. At the other end are cloud applications that schedule missions for a fleet, store terabytes of imagery and run machine learning models over it. A single project rarely touches every layer, so the first decision is always which layers you need to own and which you can build on.
The team mix follows from that choice. Firmware work needs embedded engineers who understand control loops, sensor fusion and real-time constraints. Ground, fleet and analytics work looks much more like ordinary product engineering: web and mobile developers, backend and data engineers, and machine learning engineers for the imagery. Every layer also needs people who understand flight operations, because a feature that looks sensible on a screen can be unsafe or impractical in the field. Projects that bring a licensed pilot or operations lead into design reviews early tend to avoid expensive rework later.
What are the layers of a drone software stack?
| Layer | Runs on | What it does | Typical tools |
|---|---|---|---|
| Flight control firmware | Flight controller on the drone | Stabilisation, navigation, failsafes, sensor fusion | PX4, ArduPilot, vendor firmware |
| Onboard (companion) computing | Companion computer on the drone | Payload control, onboard AI, obstacle avoidance | ROS 2, MAVSDK, embedded Linux, edge AI boards |
| Communication link | Radio, LTE/5G, satellite | Telemetry, commands and video between drone and ground | MAVLink, RF telemetry radios, cellular modems |
| Ground control | Laptop, tablet or phone | Mission planning, live monitoring, manual override | QGroundControl, Mission Planner, custom apps |
| Fleet and operations platform | Cloud or on-premises servers | Scheduling, pilot and aircraft records, maintenance, compliance logs | Custom web platforms, vendor cloud APIs |
| Data processing and analytics | Cloud, on-premises or edge | Photogrammetry, mapping, computer vision, reporting | Photogrammetry engines, GIS tools, ML pipelines |
The flight control layer keeps the aircraft safe. Everything above it is where a business differentiates: how missions are planned, how a fleet is run and how quickly raw footage becomes a decision.
Which platforms do drone software teams build on?
Very few commercial teams write a flight stack from scratch. Two open-source autopilots dominate, and manufacturer SDKs cover closed platforms.
| Option | What it is | Licence or access | Best fit |
|---|---|---|---|
| PX4 | Open-source autopilot hosted by the Dronecode Foundation | BSD 3-Clause, permissive | Products that need to keep their own changes private |
| ArduPilot | Long-running open-source autopilot for multirotors, planes, rovers and boats | GPLv3, so changes you distribute must be shared | Broad vehicle support and a large hobby and commercial community |
| MAVLink | Lightweight messaging protocol between drones, ground stations and companion computers | Open protocol | Any PX4 or ArduPilot integration |
| DJI SDKs | Mobile SDK, Payload SDK and Cloud API for DJI aircraft | Vendor developer programme | Building on widely deployed off-the-shelf DJI drones |
| ROS 2 | Robotics middleware for onboard autonomy and perception | Open source | Research-heavy autonomy, custom sensors, onboard AI |
The licence matters more than it first appears. PX4's permissive licence lets a company ship modified firmware without publishing its changes, while ArduPilot's GPLv3 licence requires distributed modifications to be released under the same terms. Teams often choose based on this as much as on features.
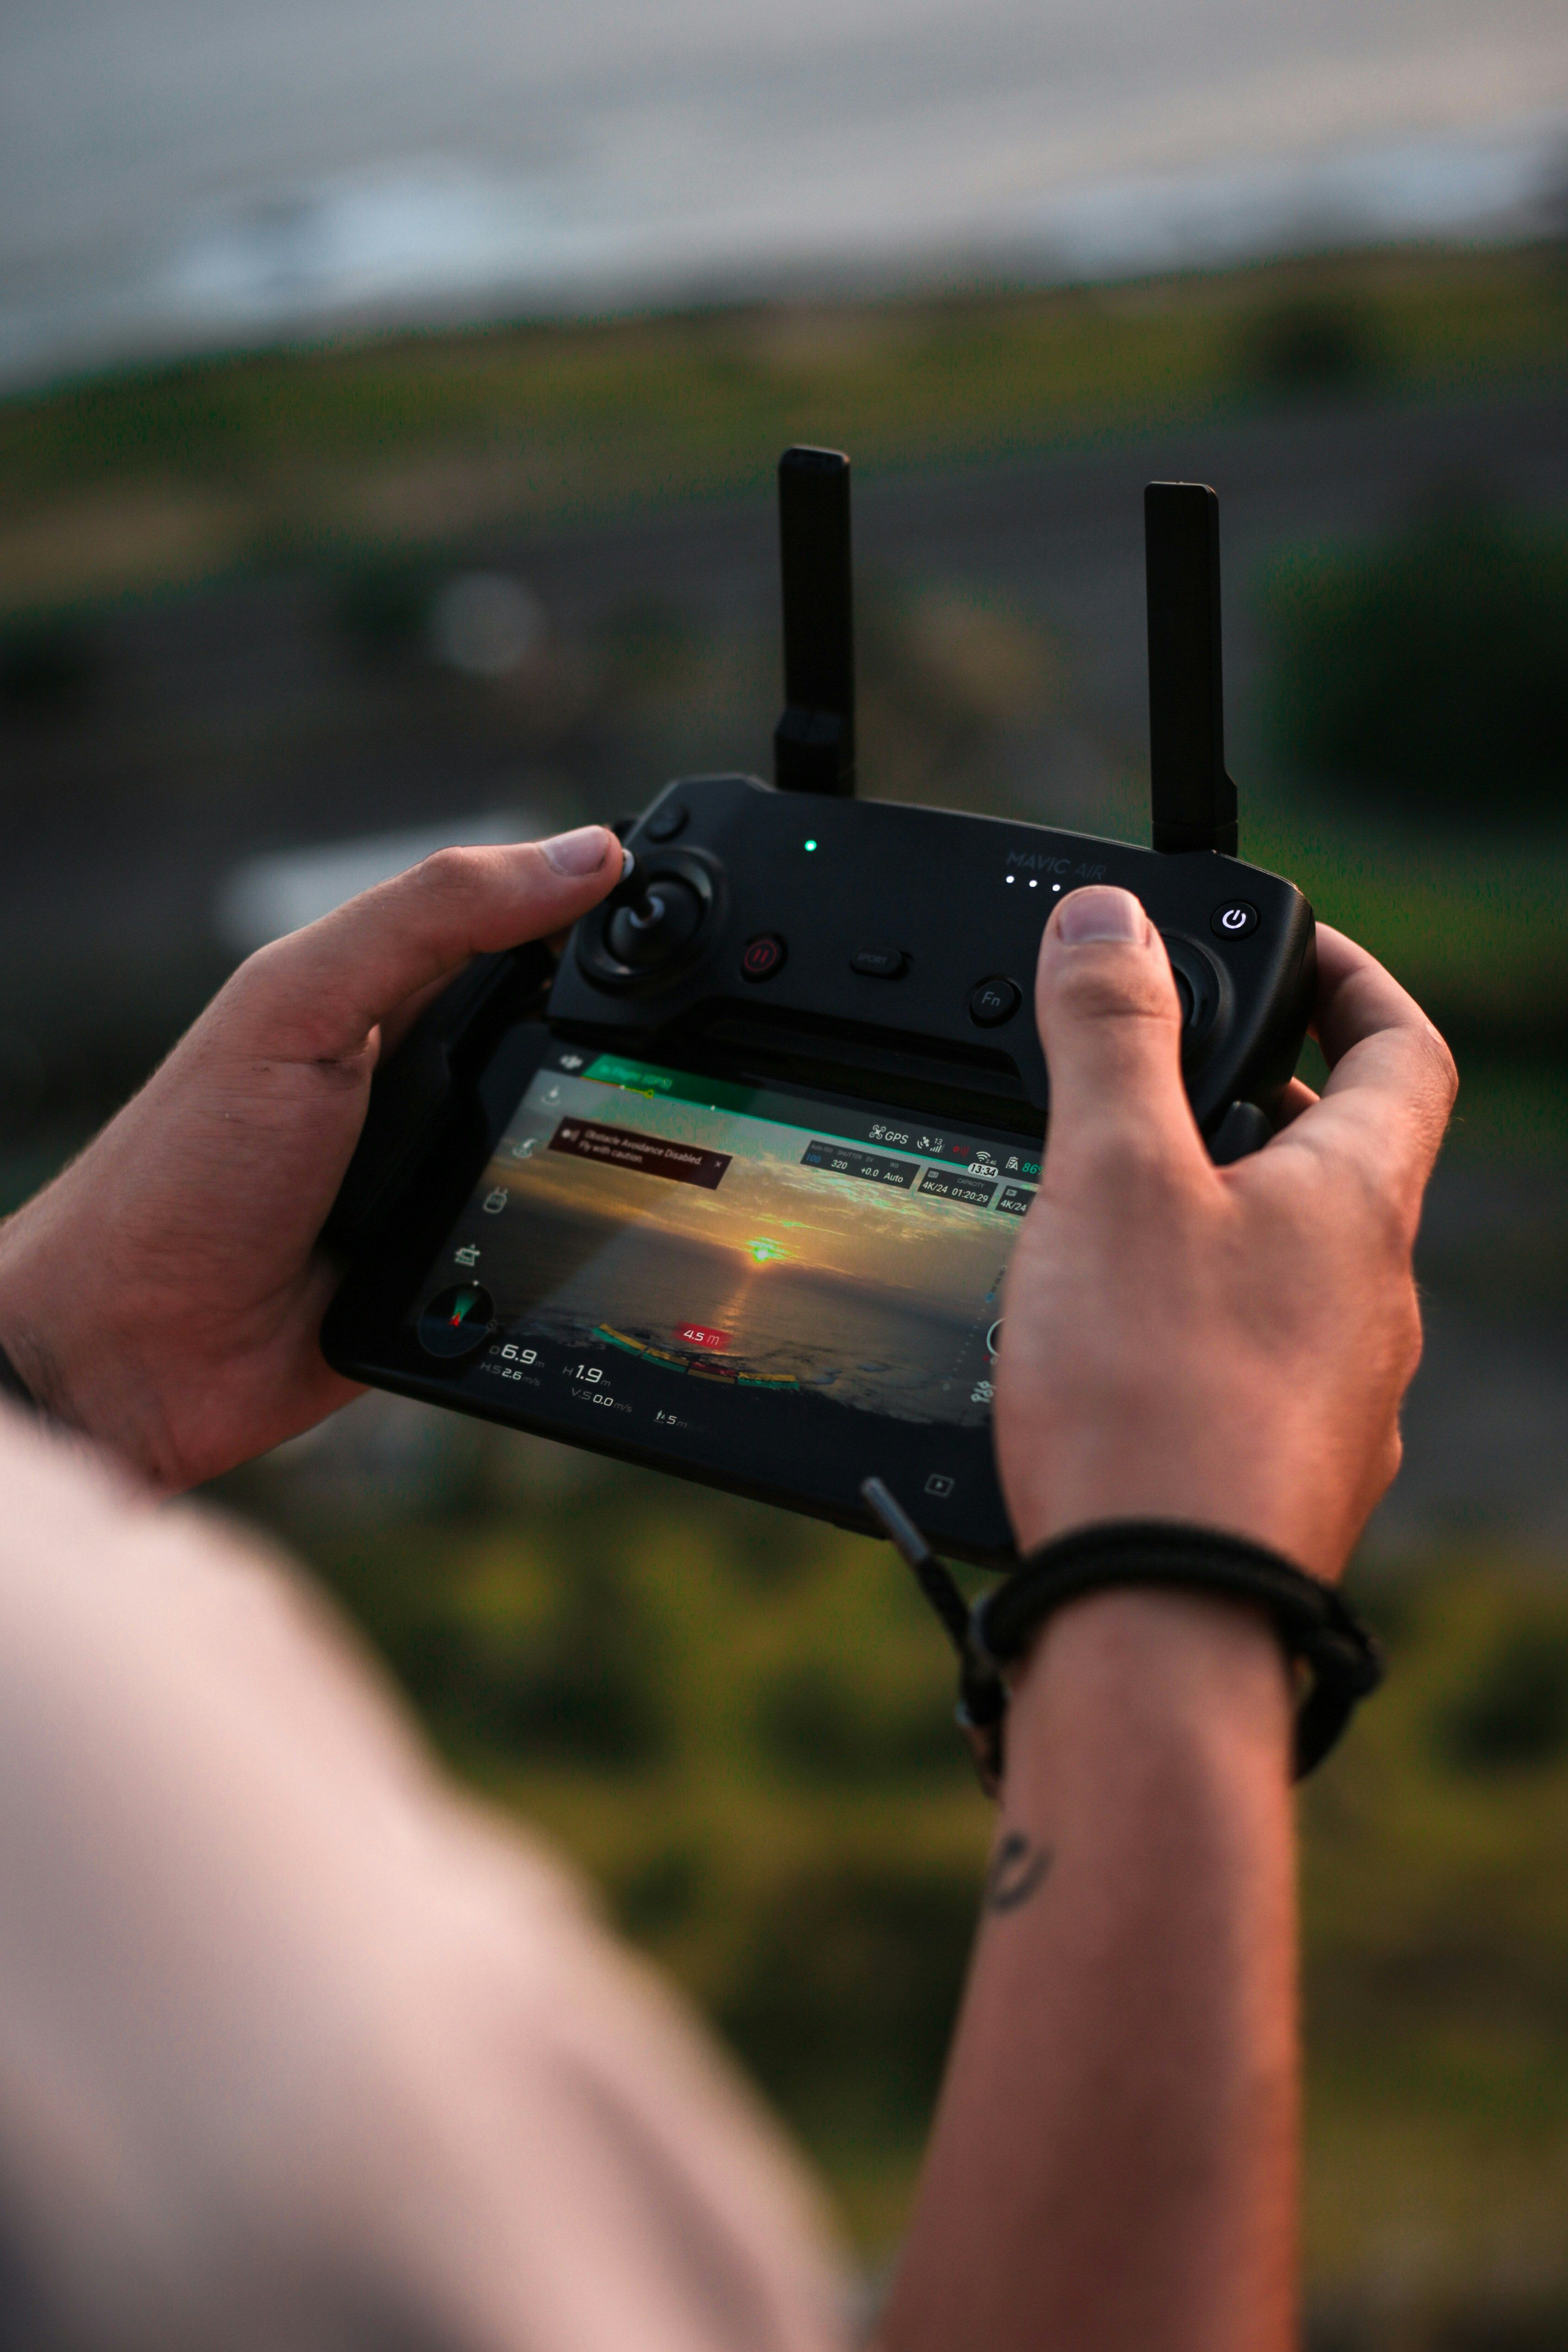
Ground control usually starts from QGroundControl, which works with both autopilots, or Mission Planner for ArduPilot. Many enterprises then build their own ground and fleet applications on top of MAVSDK or a vendor SDK, because a generic ground station does not know about their sites, assets, work orders or approval process.
What are the main use cases for drone software?
Inspection of infrastructure and industrial assets
Power lines, telecom towers, wind turbines, solar farms, pipelines, bridges and factory roofs are all inspected by drone today. The software plans repeatable flight paths, captures images at consistent angles and positions, and then compares them over time. Computer vision models can flag likely defects such as corrosion, cracks, hotspots on solar panels or vegetation encroaching on lines, so inspectors review a short list instead of thousands of photos.
Mapping, surveying and construction progress
Photogrammetry software stitches overlapping images into orthomosaic maps, digital surface models and 3D point clouds. Construction and mining teams use these to measure stockpile volumes, track earthworks and compare progress against design. The software's job is accuracy and repeatability: the same flight plan, the same overlap and the same ground control points every time.
Agriculture
Drones with multispectral cameras capture data that software turns into vegetation indices such as NDVI, highlighting stressed areas of a field. Spray drones use the same planning and mapping layers to apply inputs only where they are needed. In India, agricultural spraying has been one of the fastest-growing commercial uses.
Security and perimeter monitoring
For large sites such as plants, warehouses and solar parks, software can run scheduled patrol routes, stream live video to a control room and raise alerts when motion or people are detected in restricted zones. Geofencing keeps the aircraft inside approved boundaries.
Logistics and delivery
Delivery systems add route planning, payload release logic, landing-site management and integration with order systems. They also face the strictest regulatory hurdles, because useful delivery usually means flying beyond the pilot's visual line of sight.
How do drone regulations shape the software?
Regulation decides what the software must enforce, record and report. It is easier to design for it from the start than to bolt it on later.
| Requirement | India (Drone Rules, 2021) | United States (FAA) |
|---|---|---|
| Registration | Drones need a unique identification number issued through the Digital Sky platform | Drones over 250 g, and all drones flown under Part 107, must be registered with the FAA |
| Pilot qualification | Remote pilot certificate from a DGCA-authorised training organisation, for most non-nano drones | Remote pilot certificate under Part 107 for commercial flights |
| Airspace | Green, yellow and red zones on the Digital Sky airspace map; green zones up to 400 feet need no flight permission | Controlled airspace needs authorisation, often through LAANC; the standard ceiling is 400 feet above ground level |
| Line of sight | Operations beyond visual line of sight need specific approval | Part 107 requires visual line of sight unless a waiver or exemption is granted |
| Identification | The rules provide for safety features such as real-time tracking, which the government can make mandatory | Remote ID broadcast is required for most drones under the FAA's Remote ID rule |
In practice this turns into features. Mission planning should check airspace zones before a flight is approved. The ground and fleet apps should store pilot certificates, aircraft registration and maintenance status, and block a flight if any of them has lapsed. Flight logs should be kept in a form that can be produced for an audit. Rules change, so treat the table as orientation and check the current text from the Ministry of Civil Aviation, DGCA and FAA before you design.
How does AI fit into drone software?
AI shows up in two places. Onboard, models running on a companion computer help with obstacle avoidance, precision landing and tracking a target, where decisions have to be made in milliseconds without a network link. On the ground or in the cloud, larger models analyse the imagery after the flight: detecting defects, counting objects, classifying land use or comparing today's survey with last month's.
Most enterprise value comes from the second category. A drone that captures 2,000 photos of a solar farm is only useful if software can tell an engineer which ten panels need attention. That is a computer vision development problem as much as a drone problem: training data that matches your assets, models that tolerate changing light and weather, and a review workflow so people can confirm or reject what the model flags.
How is a drone software project built and tested?
- Define the mission, not the drone. Start from the outcome, such as weekly roof inspections across 40 sites, and work back to the data, accuracy and flight patterns required.
- Choose the platform. Decide between PX4, ArduPilot or a vendor SDK, based on the aircraft you will fly, licence constraints and the payloads you need.
- Design the operations layer. Model sites, assets, pilots, aircraft, approvals and maintenance before writing screens. This is usually where off-the-shelf tools fall short.
- Build in simulation first. Software-in-the-loop simulation, for example with Gazebo, lets you test missions and failsafes without risking an aircraft.
- Move to hardware-in-the-loop, then supervised flights. Run the real flight controller against simulated sensors, then fly in a controlled area with a safety pilot ready to take over.
- Build the data pipeline. Automate upload, processing, analysis and reporting so results reach the people who act on them.
- Operate and improve. Monitor flight logs, model accuracy and user feedback, and release updates through the same simulation and test gates.
What are the common challenges?
| Challenge | Why it is hard | How teams handle it |
|---|---|---|
| Safety-critical changes | A bug can crash an aircraft or hurt someone | Simulation, hardware-in-the-loop tests and staged rollouts |
| Connectivity | Rural and industrial sites often have weak networks | Store-and-forward uploads and onboard processing |
| Data volume | One survey can produce tens of gigabytes | Edge pre-processing and automated cloud pipelines |
| Changing regulations | Rules and airspace maps are updated | Keep compliance checks configurable, not hard-coded |
| Mixed fleets | Different aircraft speak different SDKs | An abstraction layer over MAVLink and vendor SDKs |
Should you build custom drone software or buy it?
Buy when an existing product already covers your workflow: standard mapping, a single drone brand and no need to connect results to your own systems. Build, or extend an open platform, when you run a mixed fleet, need to enforce your own approval and compliance rules, or need results to flow into your maintenance, asset or ERP systems automatically.
Many organisations end up in between: they keep a proven flight stack and commercial photogrammetry, and build the fleet, workflow and analytics layer that is specific to their operations. That layer is the focus of drone fleet management software development at Perimattic, covering mission planning, fleet and pilot records, inspection workflows and the analytics that sit on top of the flight data.